Georgia Tech / Undergraduate research
K-Scale
robotic arm
Machining parts for the arm assembly.
My fabrication work on the K-Scale arm included machined shafts, pulleys, and waterjet-cut structural plates. Working from engineering drawings, I made components for Georgia Tech’s Agile Locomotion & Manipulation VIP.
Explore the parts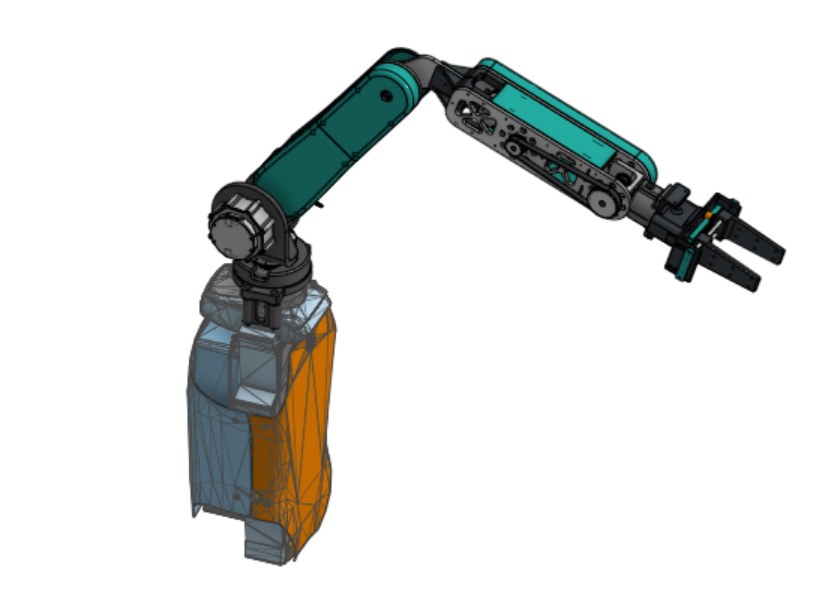
Part fabrication
From drawing to component
Select a part to explore its CAD and drawing.
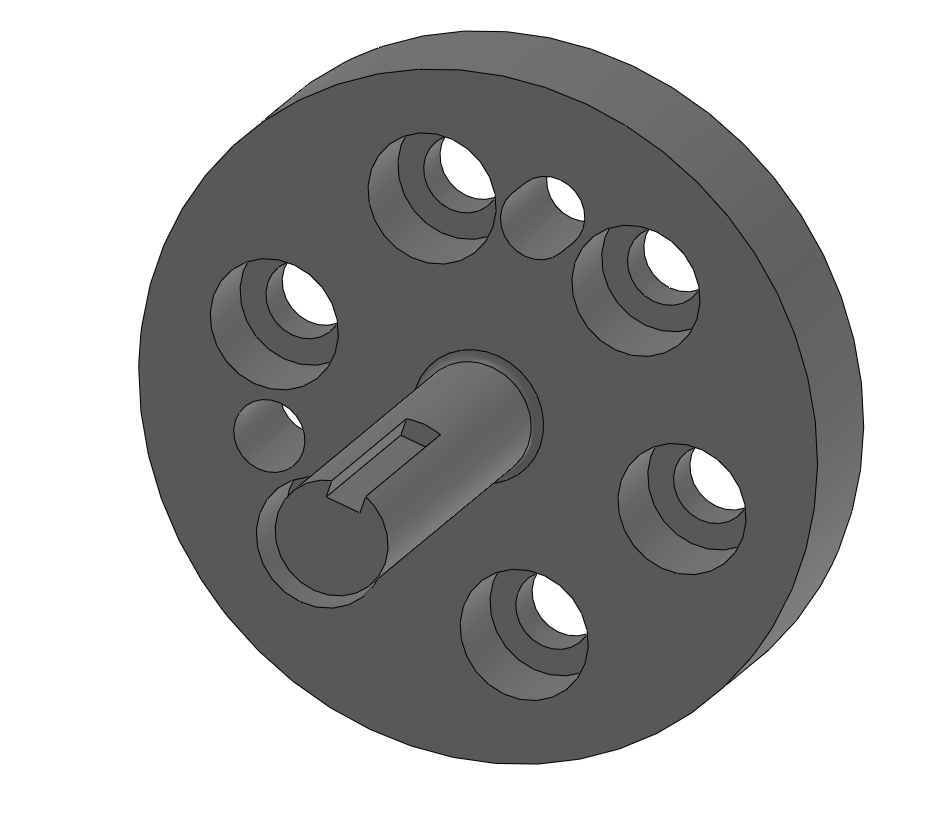
Motor input coupler shaft
This machined coupler combines a keyed shaft with a mounting flange. The drawing calls out the shaft fit, keyway dimensions, and counterbored mounting holes.