Georgia Tech / Mechanical engineering
Autonomous
robot
Five tasks. Forty seconds.
Built for a 40-second autonomous competition, this robot combined a launcher, passive carousel, and folding delivery arms on one compact chassis. I created the full SolidWorks assembly and developed the launcher, then fabricated and tested the robot with three teammates.
Explore the mechanismsFinal design
Inside the robot
One motor drives the chassis. A single pneumatic cylinder releases the launcher and swings the delivery arms. MDF decks, aluminum axles and arms, and custom 3D-printed parts keep the assembly within the size and budget limits.
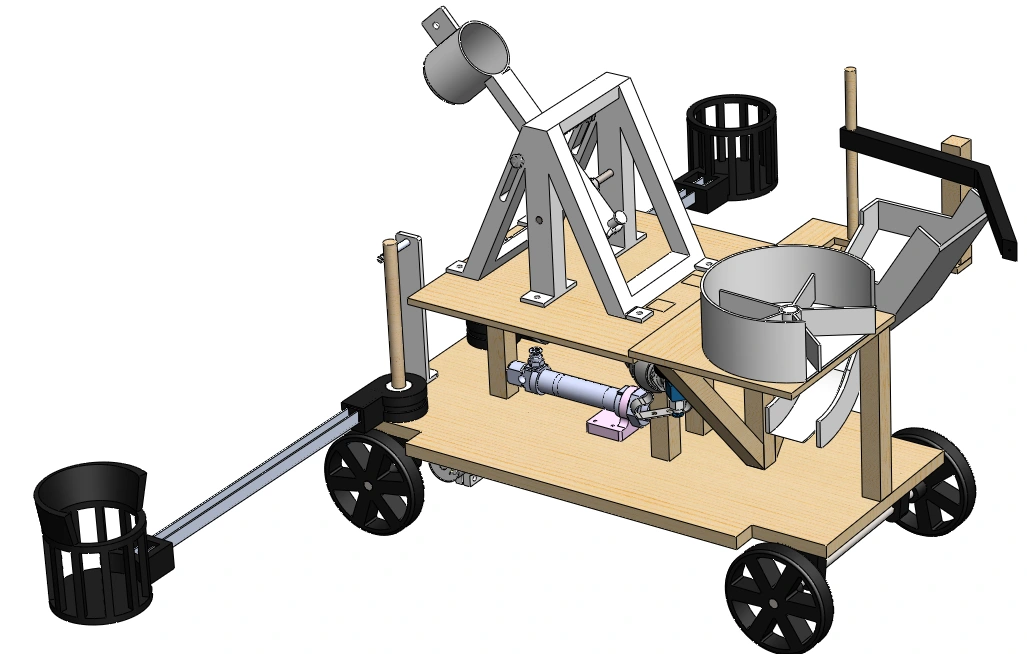
Select a mechanism to see its geometry and role.
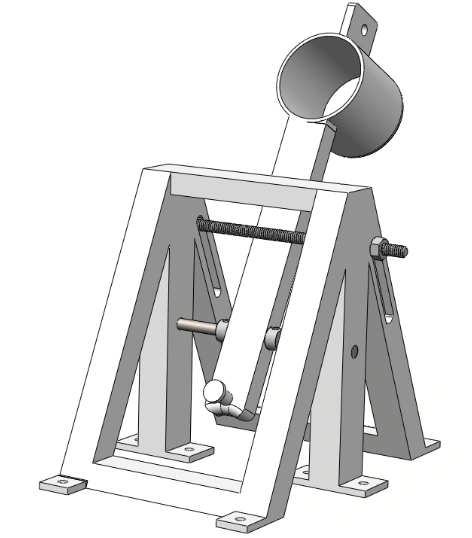
Pneumatic-release launcher
Rubber bands store the launch energy, and the pneumatic cylinder pulls a retaining pin to release the arm. An adjustable stop controls its travel. The launcher reached the second scoring tier in competition.